Anti-Aliasing Rendering Method for 3D gaussian splatting with Adaptive Dilation Integration.- „A High-Bandwidth Processing-In-Sensor Circuit for Convolution Calculations“.- Frequency-Decoupled Event-Based Visual Odometry.- Error Simulation System for High-Precision Time-Frequency Synchronization Based on Timestamp Transfer Mechanism.- Research on Detection and Risk Assessment of Mobile Obstacles in Underground Scenarios.- Research on Path Planning for Mobile Robots Using the DMSALA Algorithm.- High-Precision Phase Synchronization Based on Ultra-Wideband.- EndoSim: A Versatile Simulation Platform for Field-of-View Control Optimization in Endoscopic Robots.- Design and realization of ROS-based all-terrain oil and gas pipeline inspection robot.- A Swin Transformer and CLIP-based Framework for Generalized DeepFake Detection.- A Novel Three-Finger Robotic Gripper with Flexible Belt Mechanism for Precision and Compliant Grasping.- Design and Gradient-Wind Gliding Simulation of Bio-inspired Aircraft.- „From Model to Mission: Real-World Deployment of Pretrained AI in Robot Navigation“.- Aruco Marker-Based Minimap Switching and Relocalization for Efficient Large-Scale Robot Navigation.- UWB Assisted Navigation and Trajectory Tracking for Autonomous Vehicles.- 3D Pipeline Layout and Optimization Based on Path Planning and GPSO.- Design and Implementation of a Service Scheduling Mechanism for Ship Task Scheduling.- Dynamic Path Planning for UAVs Using Sine-Levy and Gaussian-Cauchy Ant Lion Optimizer with an Improved DWA Algorithm.- Booster Gym: An End-to-End Reinforcement Learning Framework for Humanoid Robot Locomotion.- Modeling of Cannula-Type Flexible Needle-Tissue Interaction Based on Nonlinear Elastic Potential Energy.- Edge-AI-Powered Magic Mirror: A Real-Time Intelligent Interaction System Integrating YOLOv8 and Ollama on Raspberry Pi.- Non-singular guidance control method for anti-side-slip of snake robots.- Entropy Regularization Enhanced Proximal Policy Optimization for Micro-mobility in MetaUrban.- Real-Time Trajectory Planning Algorithm Design and Experimental Verification in 3D Blind Scanning Scenarios.- From Optimal Control to Learning:LQR, QP and RL Comparison on Two-wheeled Balancing Robot.- Research and Implementation of Robot Obstacle Avoidance Algorithm Based on LiDAR.- An Information Evolution Analysis Framework for Range-Based Relative Positioning and Orientation.- Upper Limb Muscle Force Prediction Based on SEMG and Resistance Control of Rehabilitation Robots.- Enhanced DWA Algorithm Using Interval Type-2 Fuzzy Logic Control in Complex Environments.- Underwater Target Location via Depth-Adaptive Unsupervised Learning.- Design and Control of Special Operations Drones Equipped with Scalable Robotic Arms.- Camera View Planning for Active Visual SLAM Based on Deep Reinforcement Learning.- Research on Fruit Type Detection Based on Harvesting Robots.- Frequency Measurement Enhancement For Resonant Accelerometers and Their Application in Unmanned Cluster Collaboration.- Low-Resource Fine-tuning of Multimodal Foundation Models: A Study on Dialect Speech Recognition and Medical QA Systems.- Design of an Industrial Internet-Based Equipment Data Acquisition System: A Lightweight Implementation Scheme for HTTP Protocol.- Resource-Adaptive Multi-Task Federated Learning across Heterogeneous Devices.- Research on Emotion Recognition Based on Multi-scale Feature Extraction of Speech.- Design and realization of forest fire monitoring system based on Internet of Things (IoT).- Research on high precision image classification system based on multi-scale feature fusion and attention optimization.- A Method of Checking Prioritization of System Requirements Based On „Four Property Analysis“.-
An Improved Lightweight Dense Pedestrian Detection Algorithm Based on YOLOv11.- Advanced LED-Based Indoor Positioning and Path Planning Algorithm.- Adaptive Parameter Control Framework for Metal Tube Crimping Process Using Hybrid Fuzzy Expert System and Fuzzy-LSTM Prediction Model.- A Method for Anomaly Detection in IoT Traffic Based on Self-Supervised Deep Learning.- Research on Multi-Strategy Adaptive Framework for Retrieval-Augmented Generation.- A Comparative Study of Groq-Based and Agent-Based Models for Software Challenges Management and Optimization.- Student Classroom Behavior Detection Algorithm Based on Improved YOLOv8.- Multi-Frequency Tensor Decomposition Frameworks for Dynamic Brain Network Analysis Based on CCPD Models.- Multi-Modal Knowledge Graph and Hierarchical Graph Transformer for Software Vulnerability Analysis.- Improved MobileNetV2 fire detection system for granary scenes.- Model-driven development of ROS with LLM: ROMA (Robot Ontology Modelling Approach).- Self-Attention-BiLSTM lactation curve prediction for Test-day.- Subpixel-Level Cephalometric Ruler Scale Calibration by Keypoint Neighborhood Analysis and Fourier Analysis.- „Development of a thrust allocation algorithm for a dynamic positioning Ballast water treatmentvessel“.
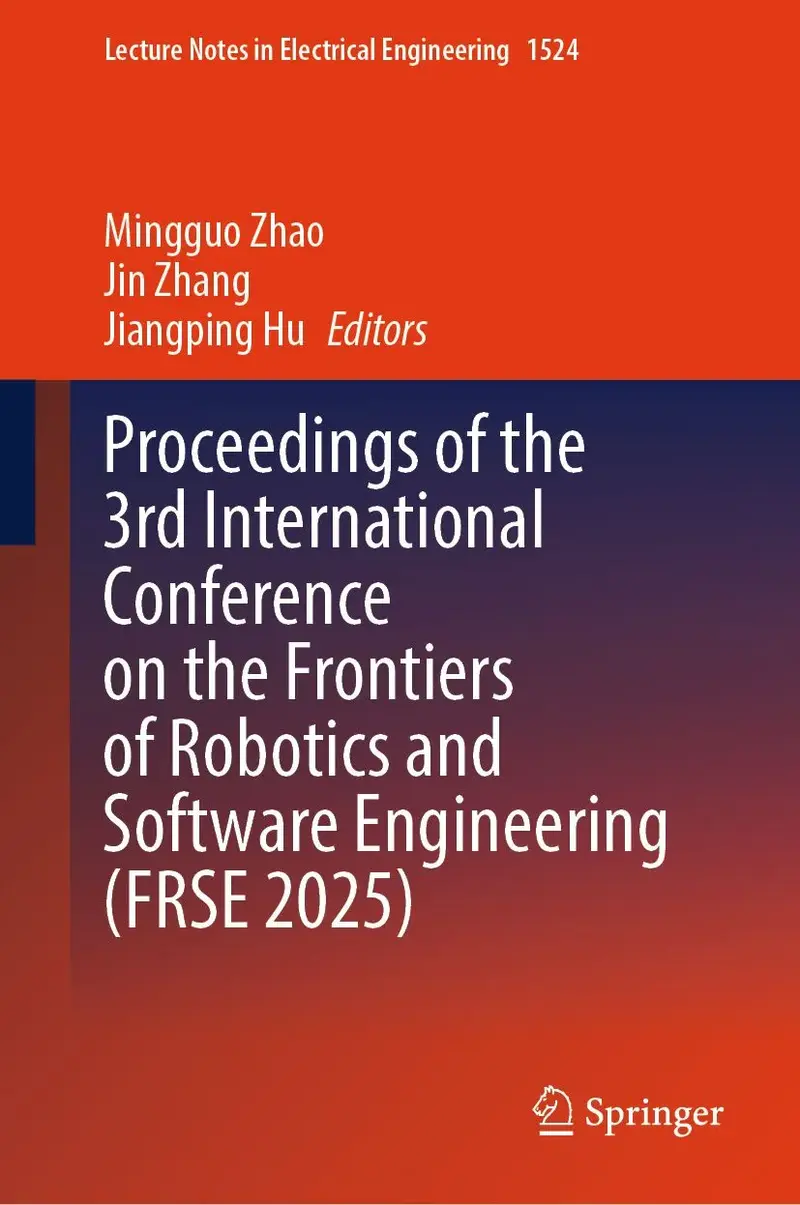
Proceedings of the 3rd International Conference on the Frontiers of Robotics and Software Engineering
Ursprünglicher Preis war: 480,43 €300,00 €Aktueller Preis ist: 300,00 €.
📍 -- Personen haben dieses Produkt kürzlich angesehen
🚚 Voraussichtliche Lieferung: Okt. 18 - Okt. 23
📦 Versandrichtlinie: Kostenloser Versand bei Bestellungen über 25 €
🛡️ 30-Tage-Rückgabe: Kostenlose Rücksendung, keine Wiederaufnahmegebühren
✉️ Kundensupport: 24/7 Unterstützung
🔒 Sicherer Checkout
Ähnliche Produkte
-
E-Book
Robotics and Mechatronics
Ursprünglicher Preis war: 298,53 €223,90 €Aktueller Preis ist: 223,90 €. In den Warenkorb -
E-Book
Amerika ’33
Ursprünglicher Preis war: 22,99 €16,09 €Aktueller Preis ist: 16,09 €. In den Warenkorb -
E-Book
Handbook of Traditional Spirituality and Sustainability
Ursprünglicher Preis war: 213,99 €160,49 €Aktueller Preis ist: 160,49 €. In den Warenkorb -
E-Book
Die Patin von New York
Ursprünglicher Preis war: 9,99 €6,99 €Aktueller Preis ist: 6,99 €. In den Warenkorb
Rezensionen
Es gibt noch keine Rezensionen.